
Elephant Robotics myCobot 320
Affordable desktop robot arm for education with Python, ROS, and visual programming.

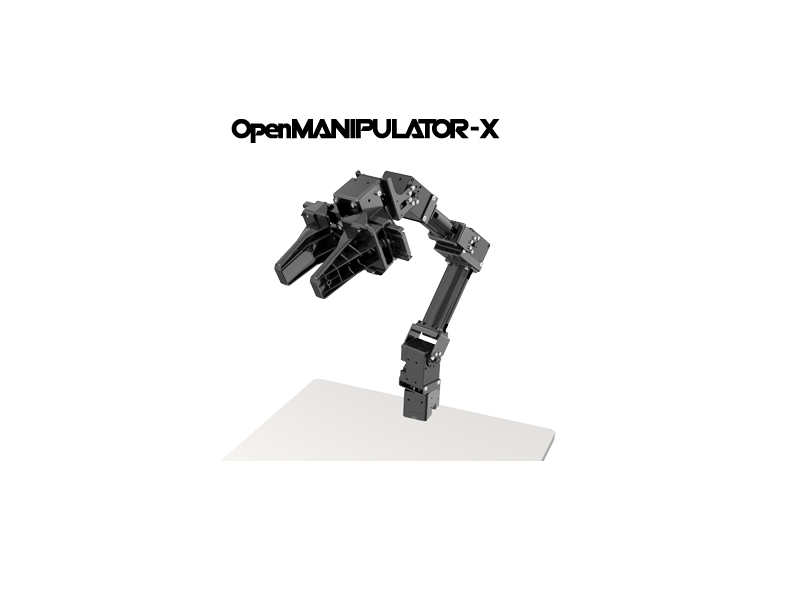
The ROBOTIS OpenManipulator-X is a fully open-source robot arm designed as the standard educational platform for learning robot manipulation with ROS. All CAD files, firmware, and software are freely available, and the complete documentation walks learners through assembly, configuration, and programming step by step.
Built with DYNAMIXEL XM430 servos, the OpenManipulator-X offers smooth, precise movement and position/velocity/current feedback from each joint. It integrates seamlessly with the TurtleBot platform for mobile manipulation experiments and includes comprehensive ROS2 packages for MoveIt, Gazebo simulation, and basic perception.
| Payload | 500g |
|---|---|
| Reach | 380 mm |
| Degrees of Freedom | 4 + gripper |
| Servos | DYNAMIXEL XM430-W350 |
| SDK | ROS2, MoveIt, Gazebo |
| Weight | 0.7 kg (1.5 lbs) |
A quick summary of where this model performs well and where it falls short.
Want to know more about the ROBOTIS OpenManipulator-X? Send us an enquiry and we'll get back to you with pricing, availability, and any details you need.
We've received your enquiry about the ROBOTIS OpenManipulator-X. We'll be in touch shortly.
Affordable desktop robot arm for education with Python, ROS, and visual programming.

Vision-integrated 12 kg cobot with built-in smart camera and flowchart programming.

DYNAMIXEL-powered research arm with ROS2, MoveIt, and mobile manipulation support.